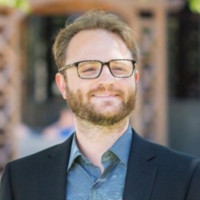
Forrest Briggs
Redefining volumetric capture, compression and rendering, for VFX and XR

Experience
Career
- 2021
Lifecast Incorporated
Chief Executive Officer · Menlo Park, California, United States · 2021 – Present
 2019
X, the moonshot factory
Technical Lead for Calibration, Senior Software Engineer (Robotics) at Google X · Mountain View · 2019 – 2021
 2017
Lyft
Technical Lead - Sensor Calibration, Autonomous Vehicle Engineering at Lyft Level 5 · Palo Alto · 2017 – 2019
 2015
Facebook
Software Engineer (Building 8) - VR Camera Systems · Meno Park · 2015 – 2017
 2014
Rocket Fuel Inc.
Machine Learning Scientist · 2014 – 2015
 2011
Revolution Robotics
Machine Vision Consultant / Developer · 2011 – 2012
- 2007
The Learning Annex LLC
Web Developer · 2007 – 2008
- 2006
Sticky Inc
Software Developer · 2006 – 2007
 2005
SoundSpectrum, Inc.
Software Developer · 2005 – 2007
 2005
JPL (NASA's Jet Propulsion Laboratory)
Intern · 2005
Bio
Forrest (CEO at Lifecast) has a Ph.D. in machine learning and over 20 patents in VR video and AI perception systems. He previously developed computer-vision based VR video rendering software at Facebook, and was a tech lead at Lyft and Google X working on perception systems for self-driving cars and robots.